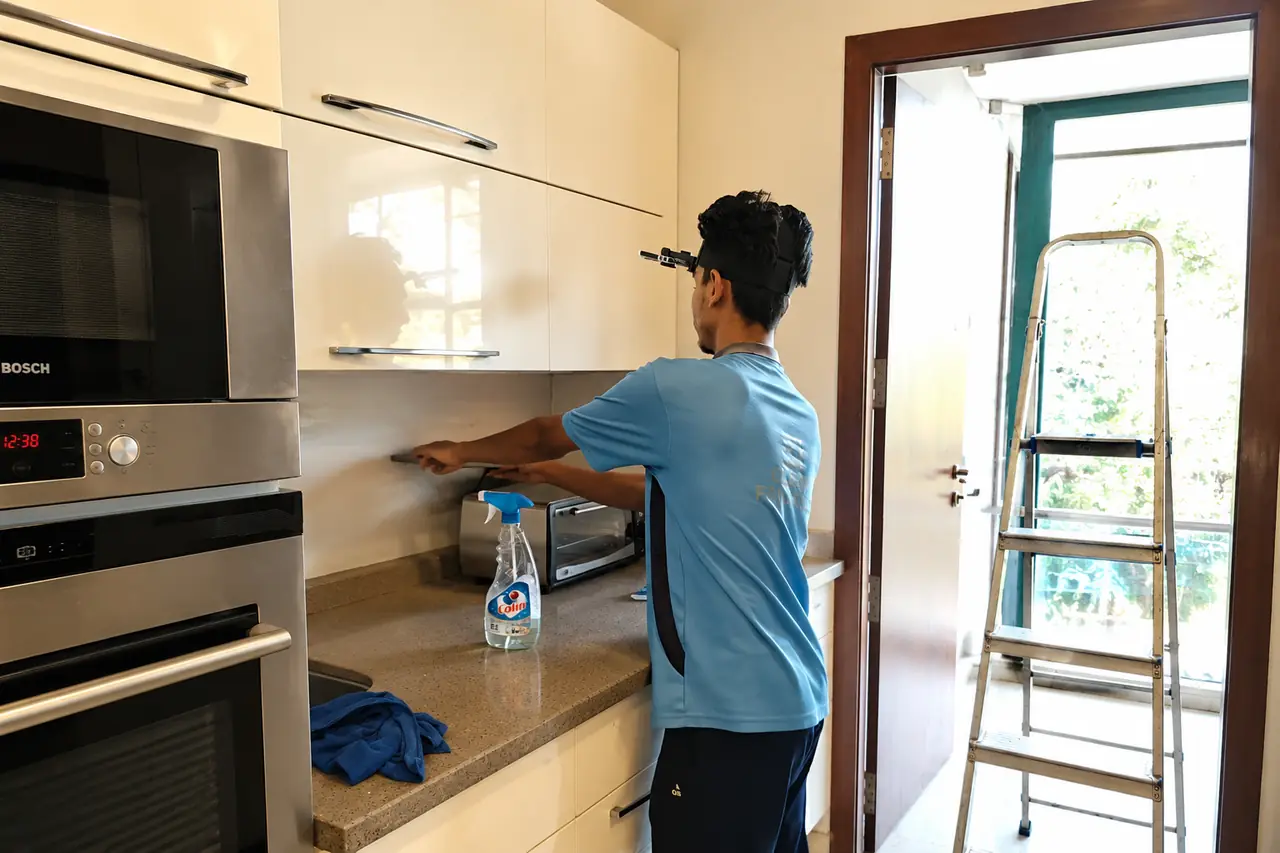
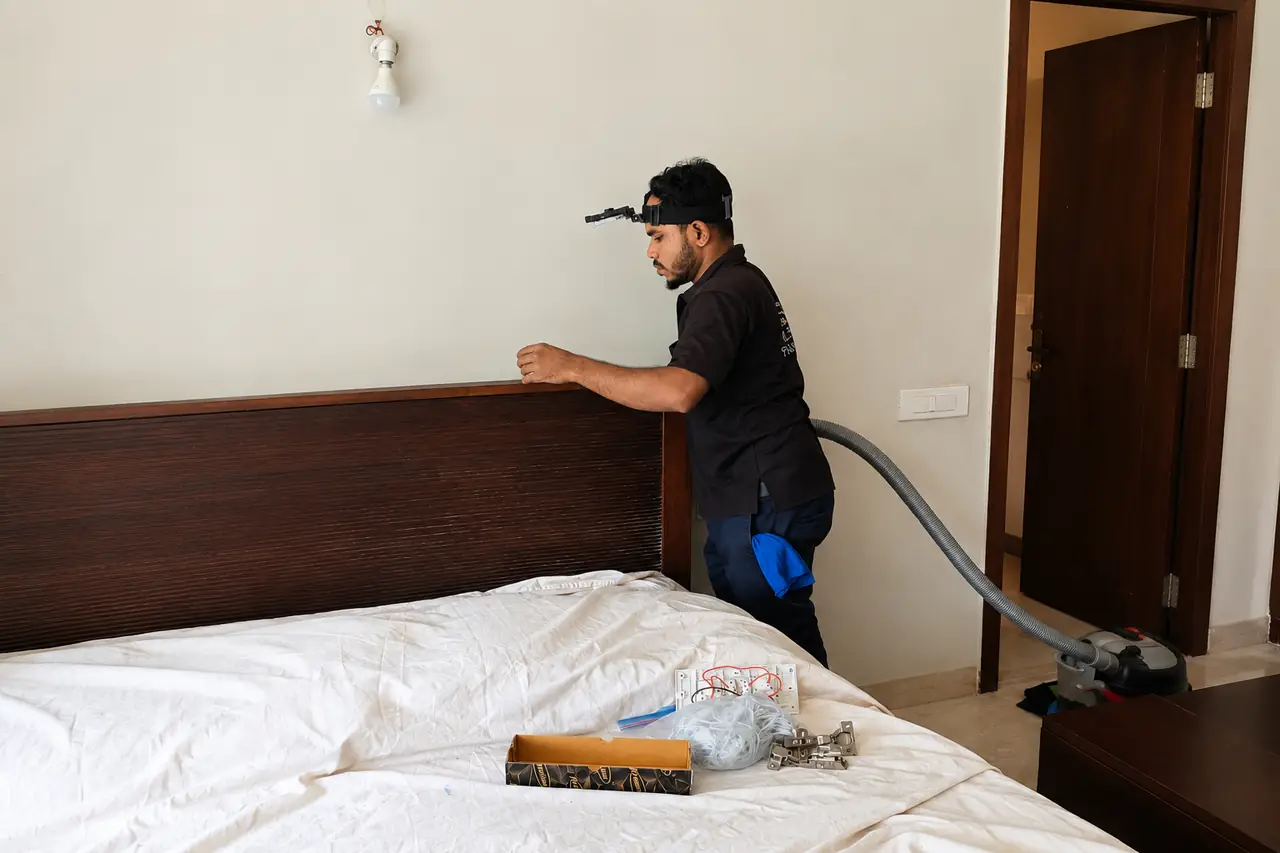
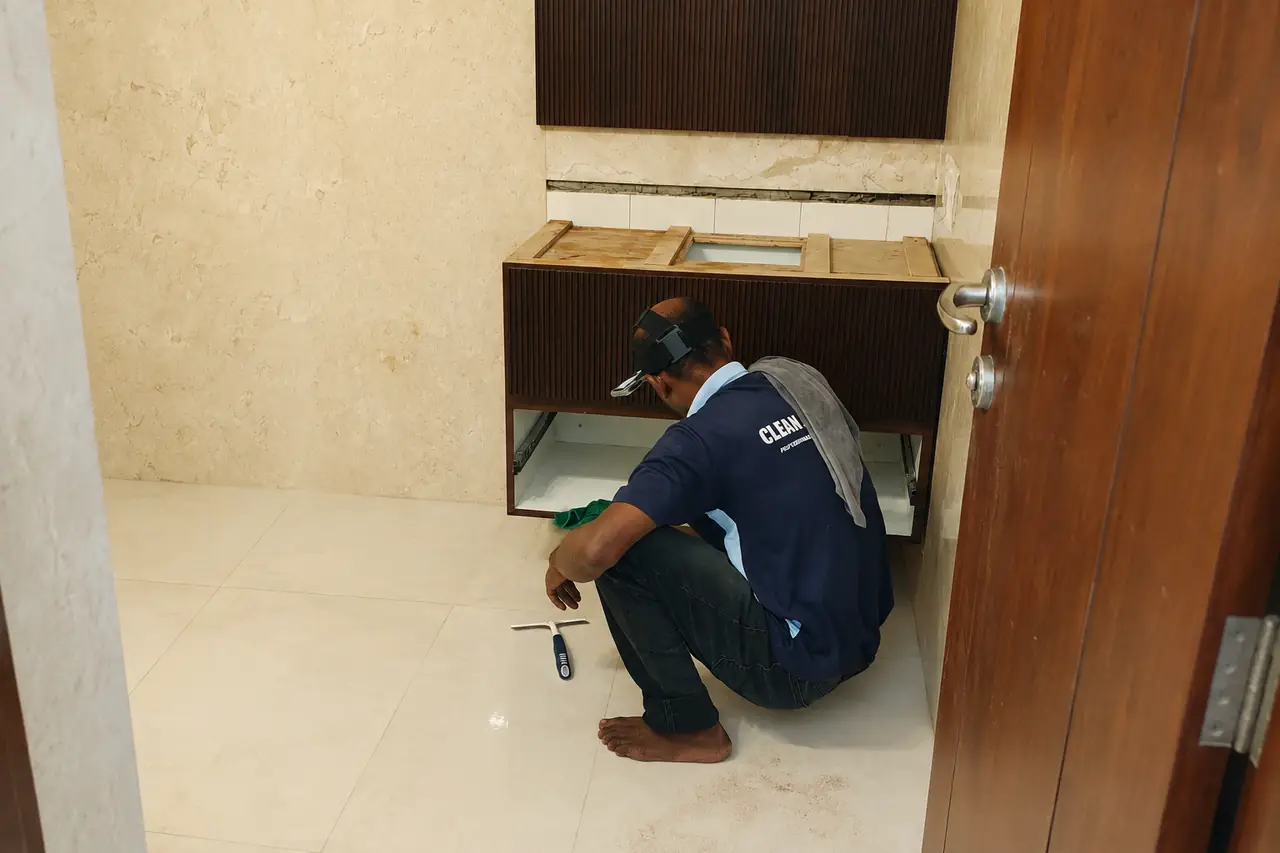
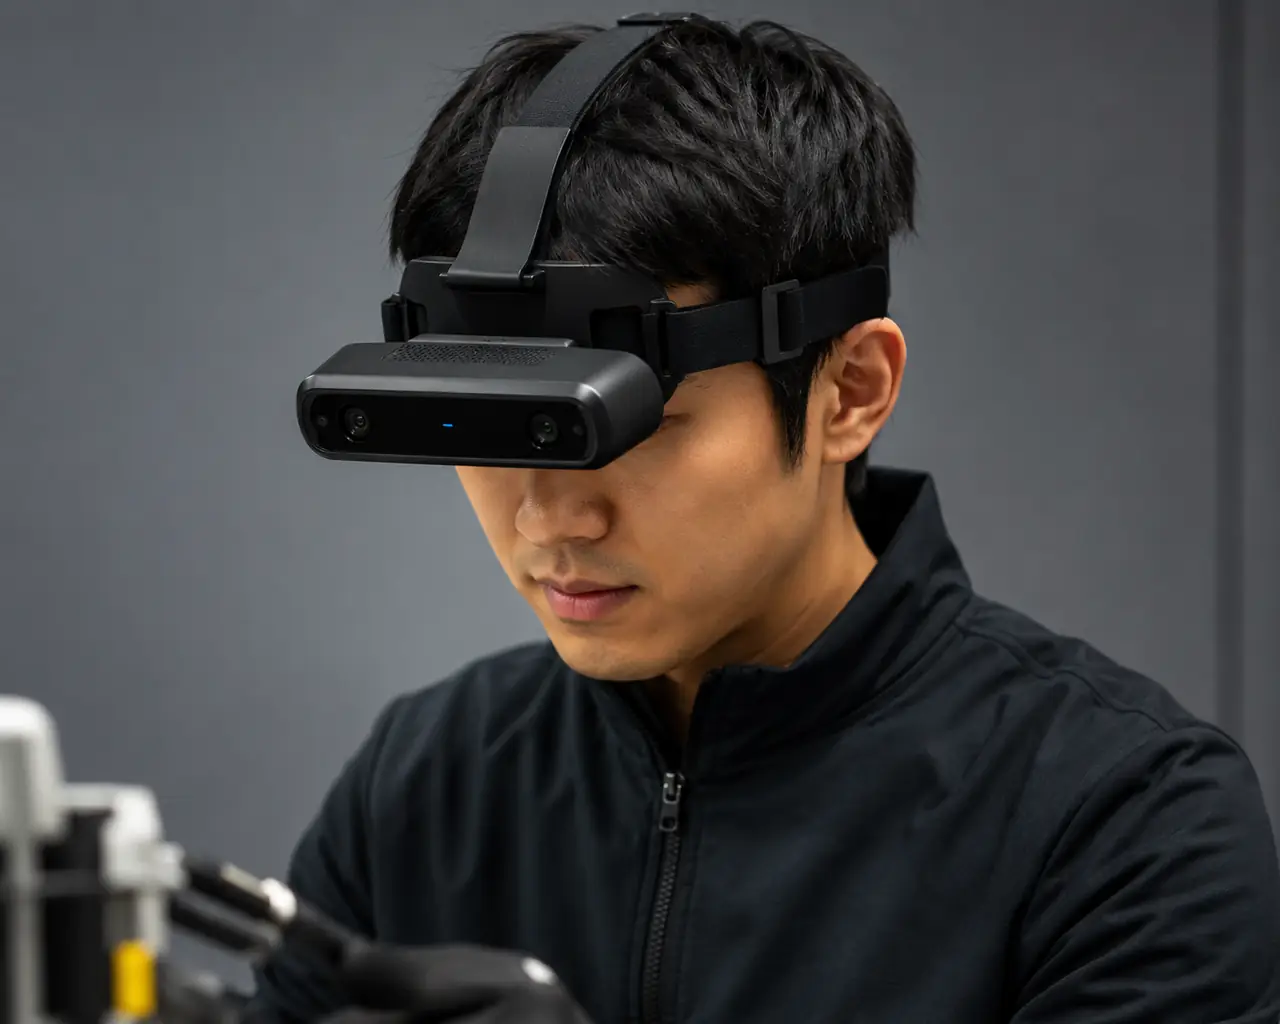
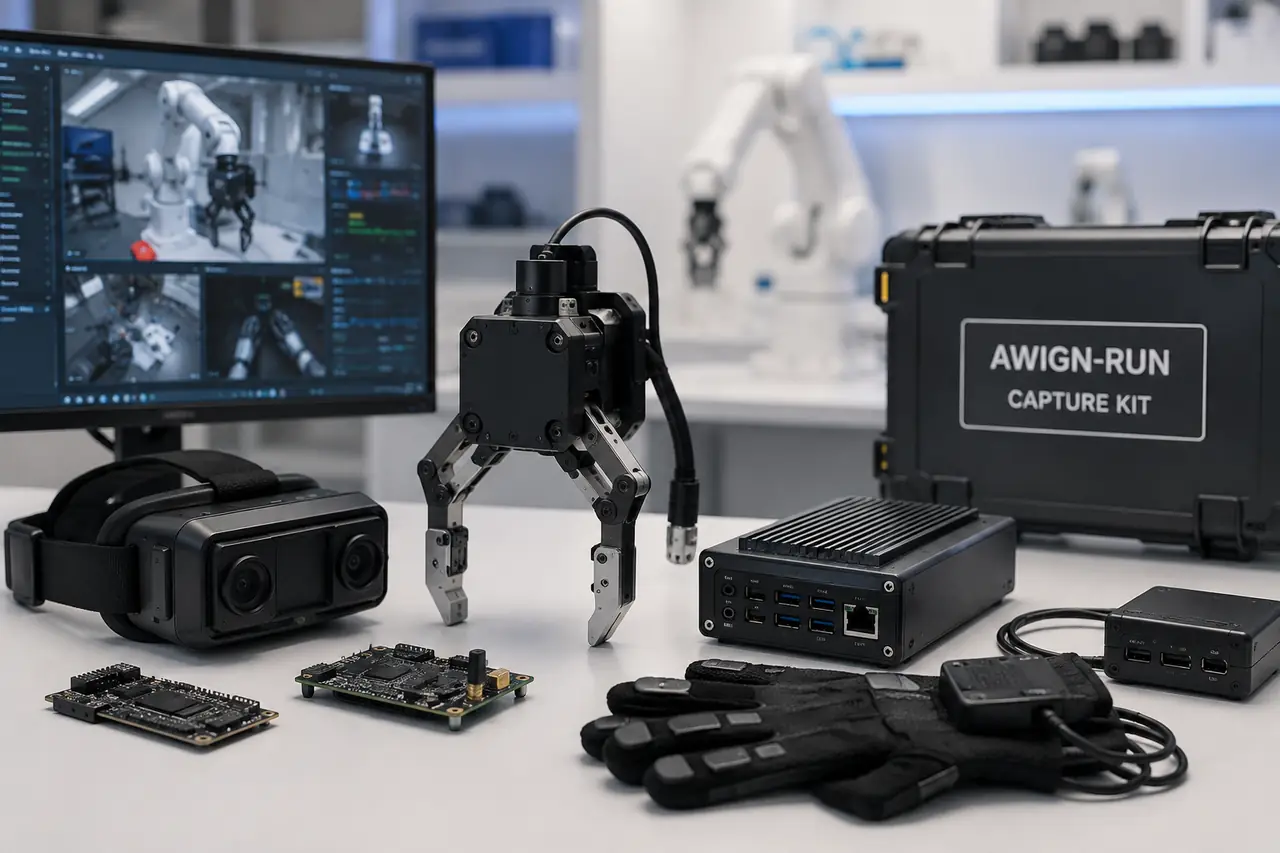
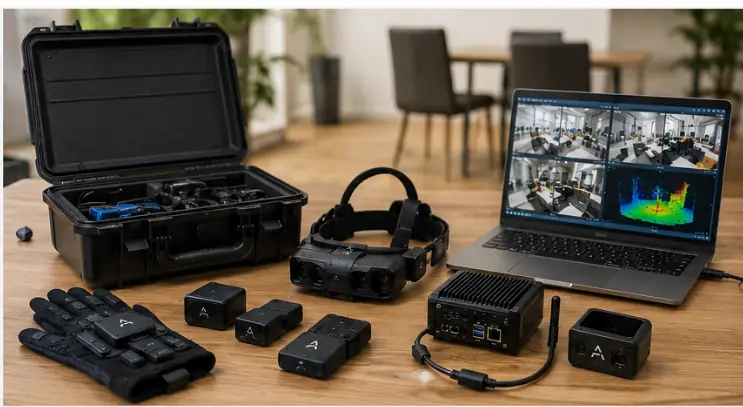
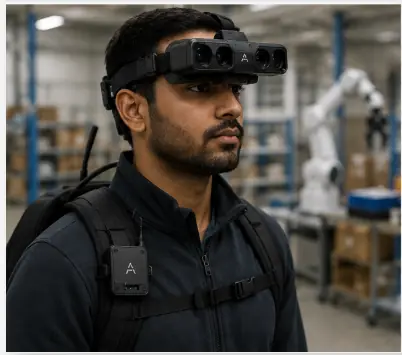
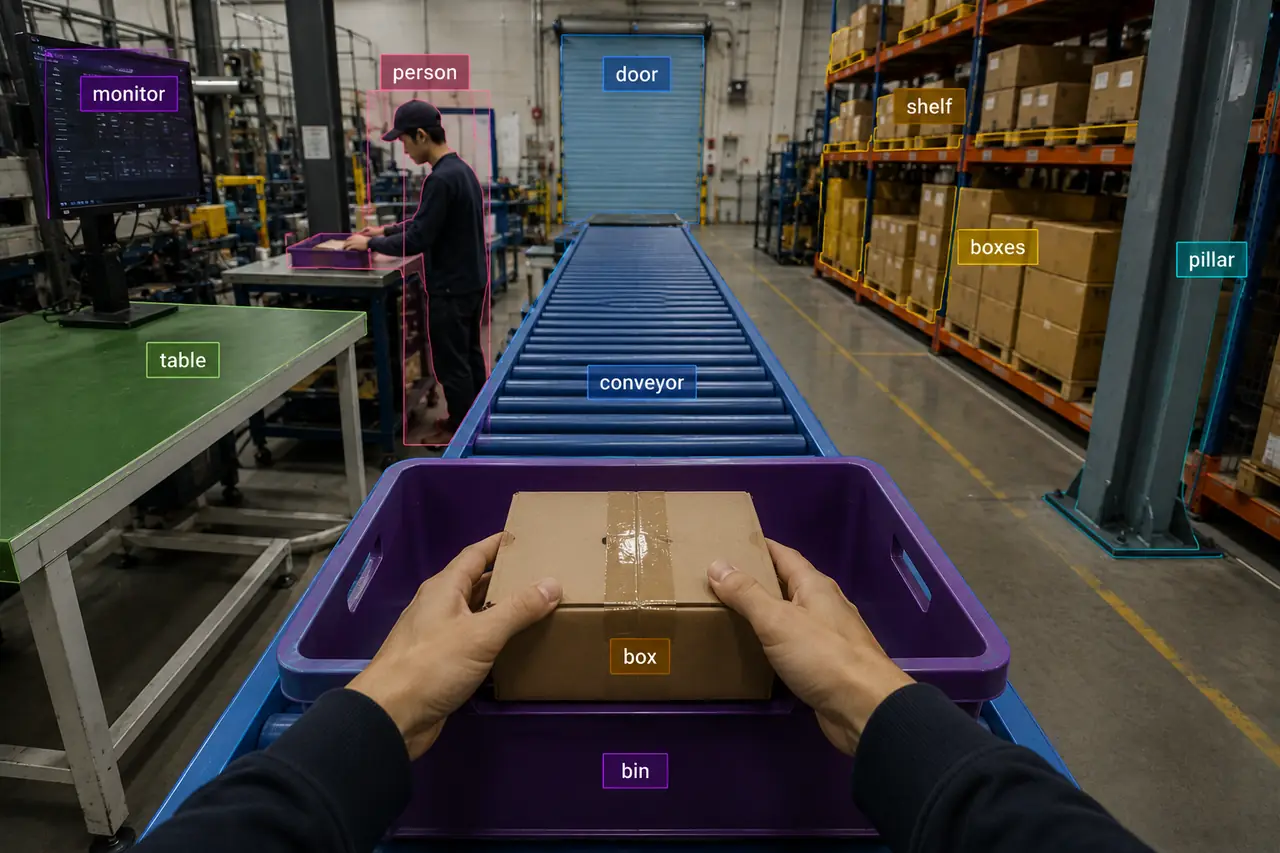
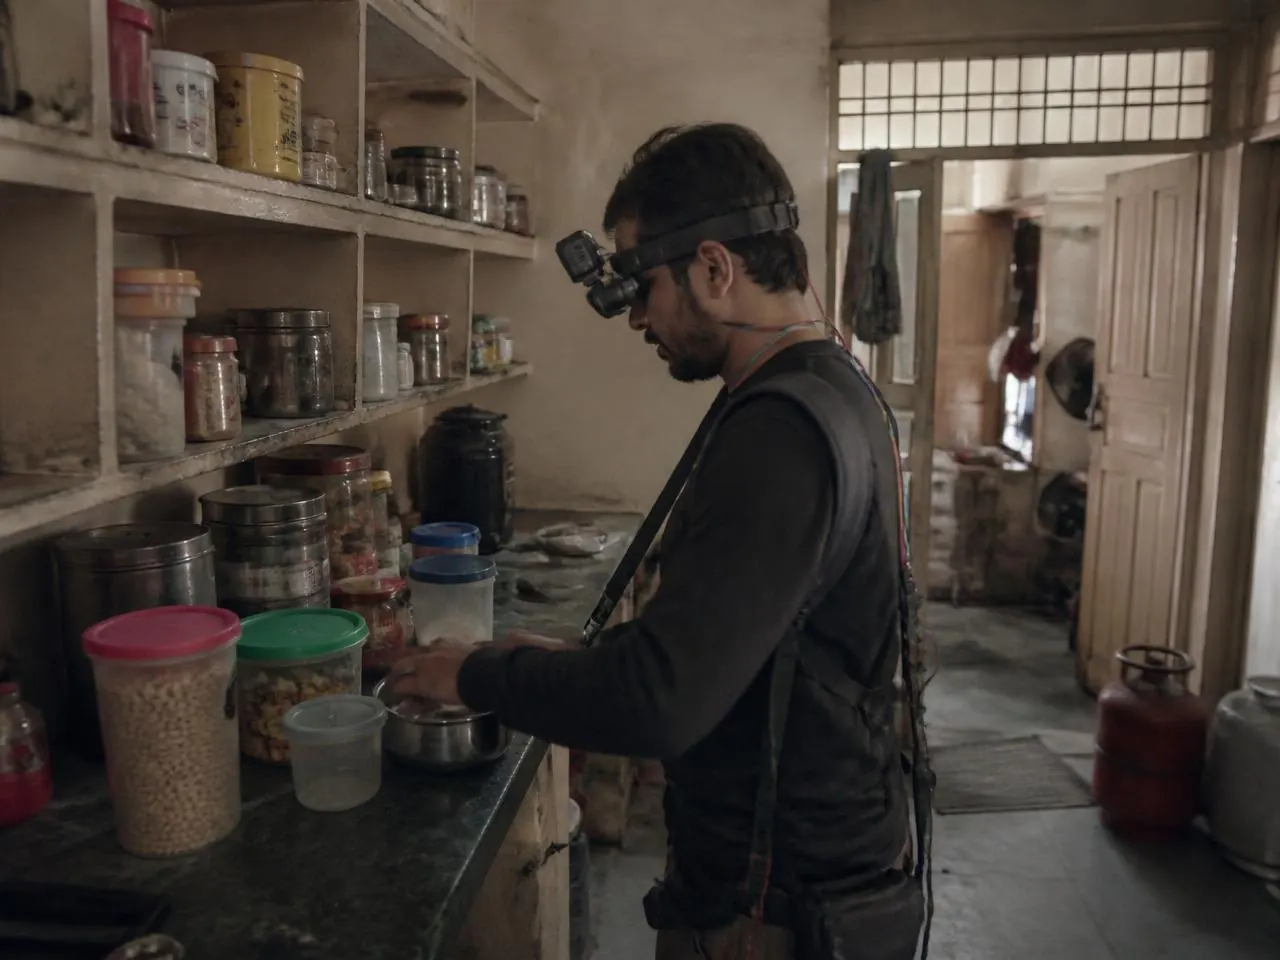
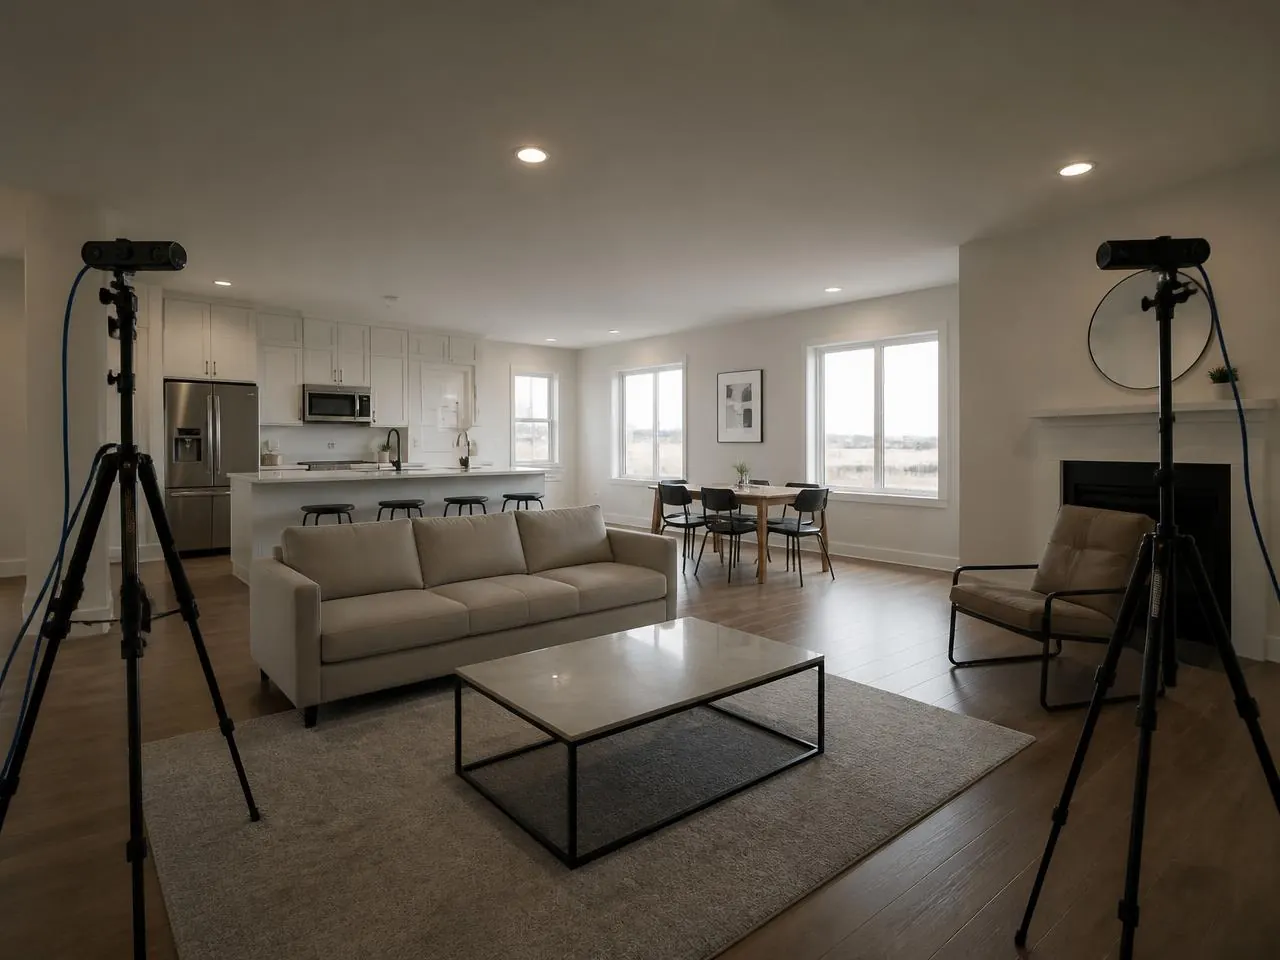
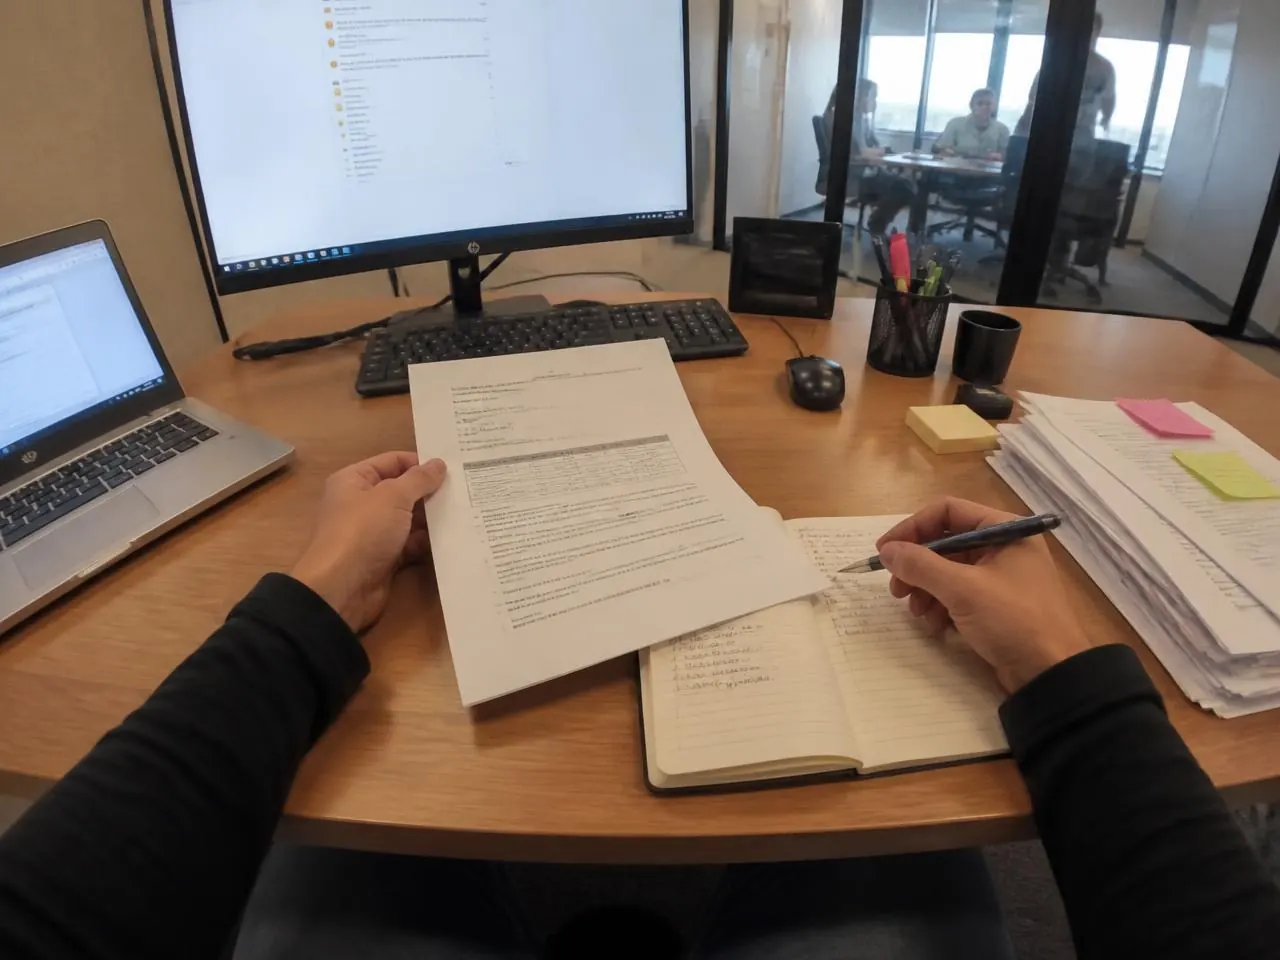
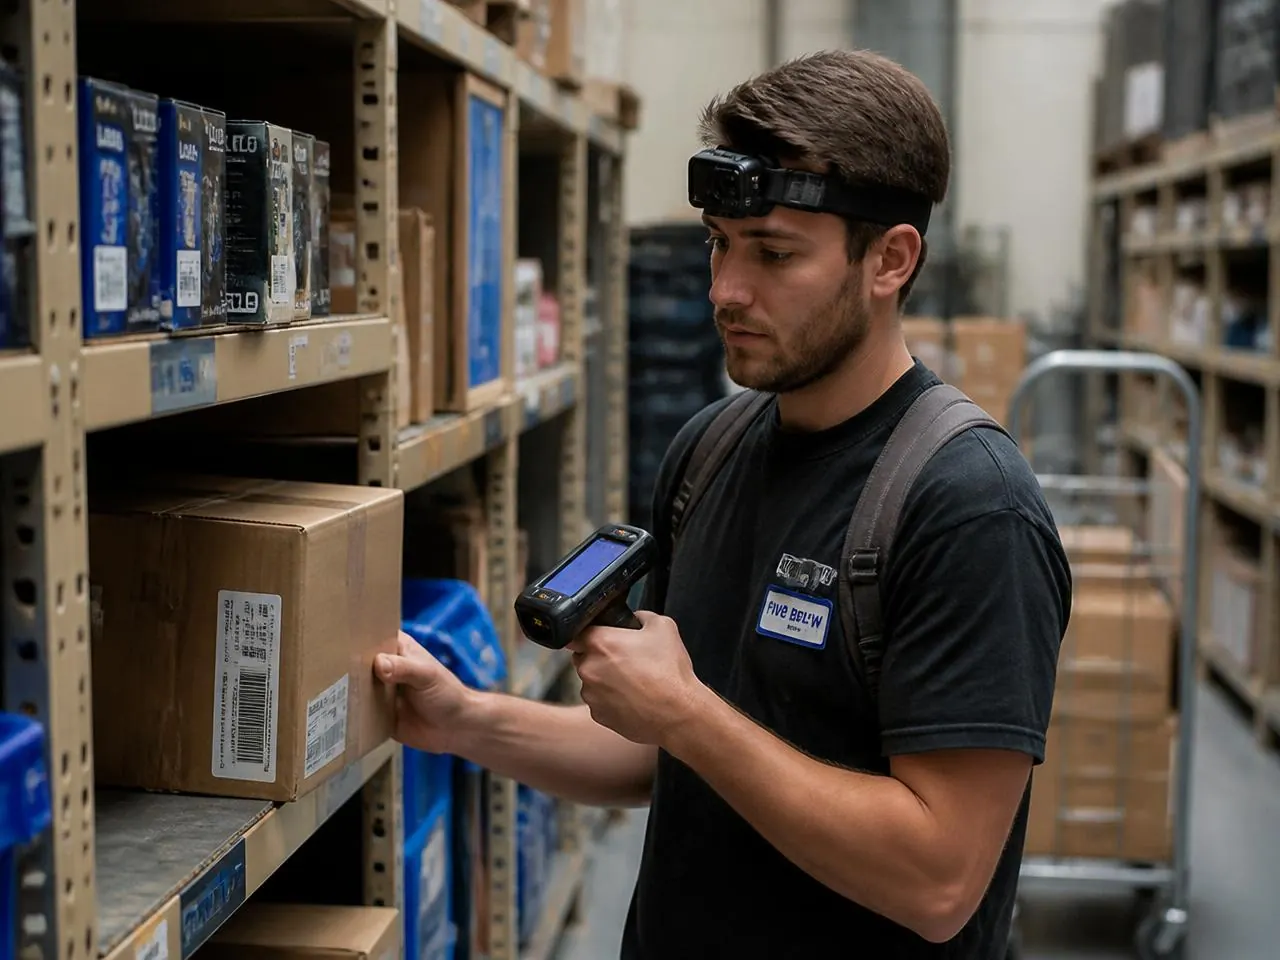
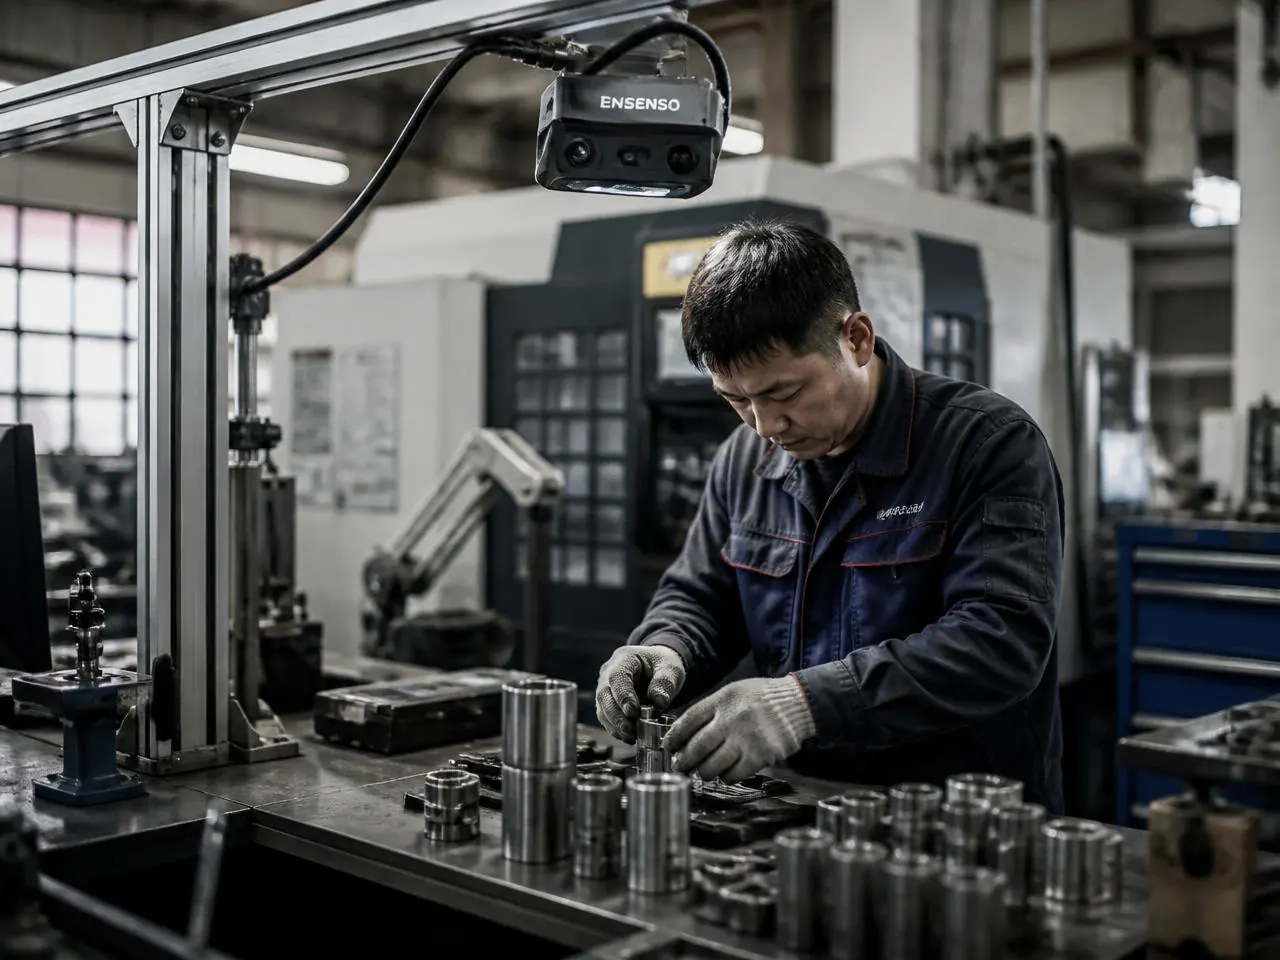
Collect large-scale Ego data and human demonstration datasets using head-mounted cameras. We handle end-to-end data collection, operations, annotation and QA
services for Physical AI, humanoid robotics, dexterous manipulation, embodied AI and robot foundation models.
Choose the task, hardware, environment, and production-ready data across real-world environments—powered by India’s largest Human Operations platform.
Awign is India's largest human operations company with 1.5M+ workers, operations across 1,000+ cities, and the ability to manage complex work at large scale.
For robotics companies, we turn this workforce and operating infrastructure into a dedicated data production layer for egocentric video, sensor-based capture,
teleoperation, and semantic annotation. You bring the robotics problem. We bring the people, places, SOPs, execution, and quality control.
See how Awign builds robotics data production lines — from SOP design and environment setup to worker deployment, capture, QA, and annotation.
1.5M+1,500,000
workers
0
cities
10K+10,000
Hrs Videos per day
98%
Labeling accuracy
Our Offerings
Choose the Data Pipeline Your Robot Needs
Start with one data collection workflow or combine multiple capabilities into a dedicated robotics data production line.
Ego Vision
Monocular RGB egocentric video at scale
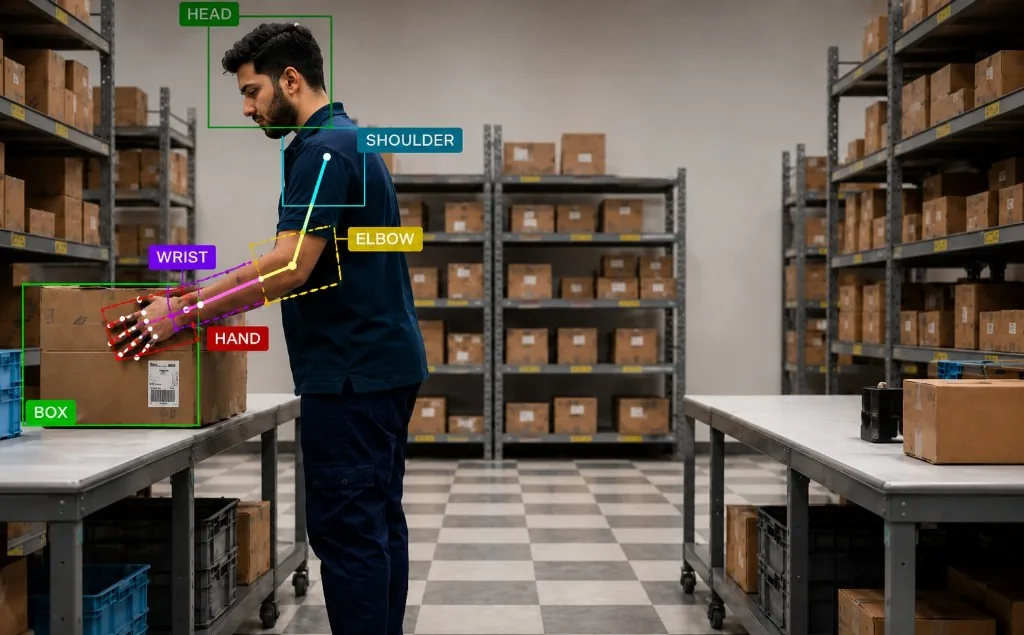
First-person RGB video of humans performing real-world tasks using monocular camera rigs. Ideal for large-scale human activity data, imitation learning, embodied AI, humanoid robotics, and manipulation datasets.
Capture setup
Monocular RGB camera rigs, phones, or client-specified RGB setups.
Deliverables
Raw RGB video, task metadata, environment metadata, QC status, and optional annotation.
Add-ons
VLM-assisted labels, HITL QA, captions, task segmentation, and 3D hand pose estimation.
Sample dataset
Show short clips such as arranging laptop accessories, arranging marker pens, arranging tea bags, sorting books, organizing shelves, or handling tools.
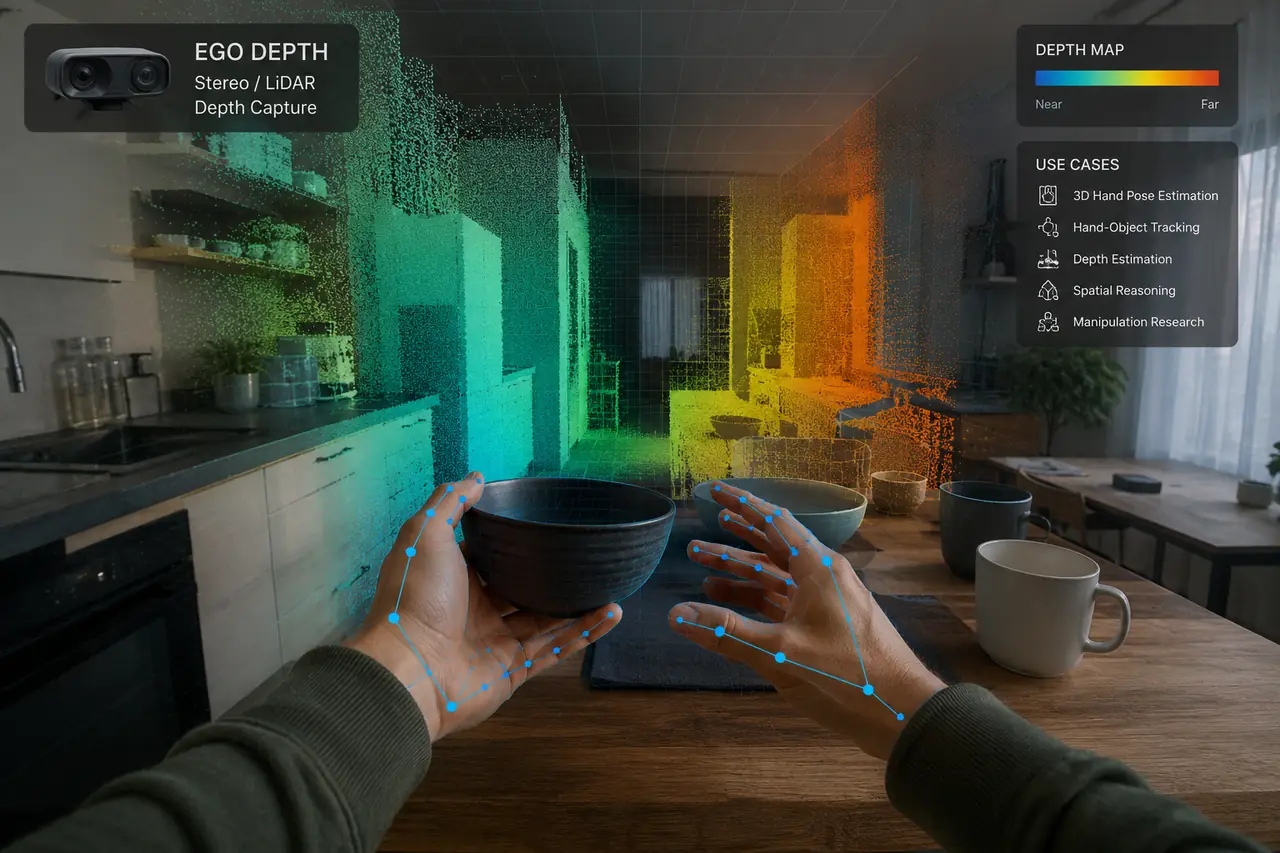
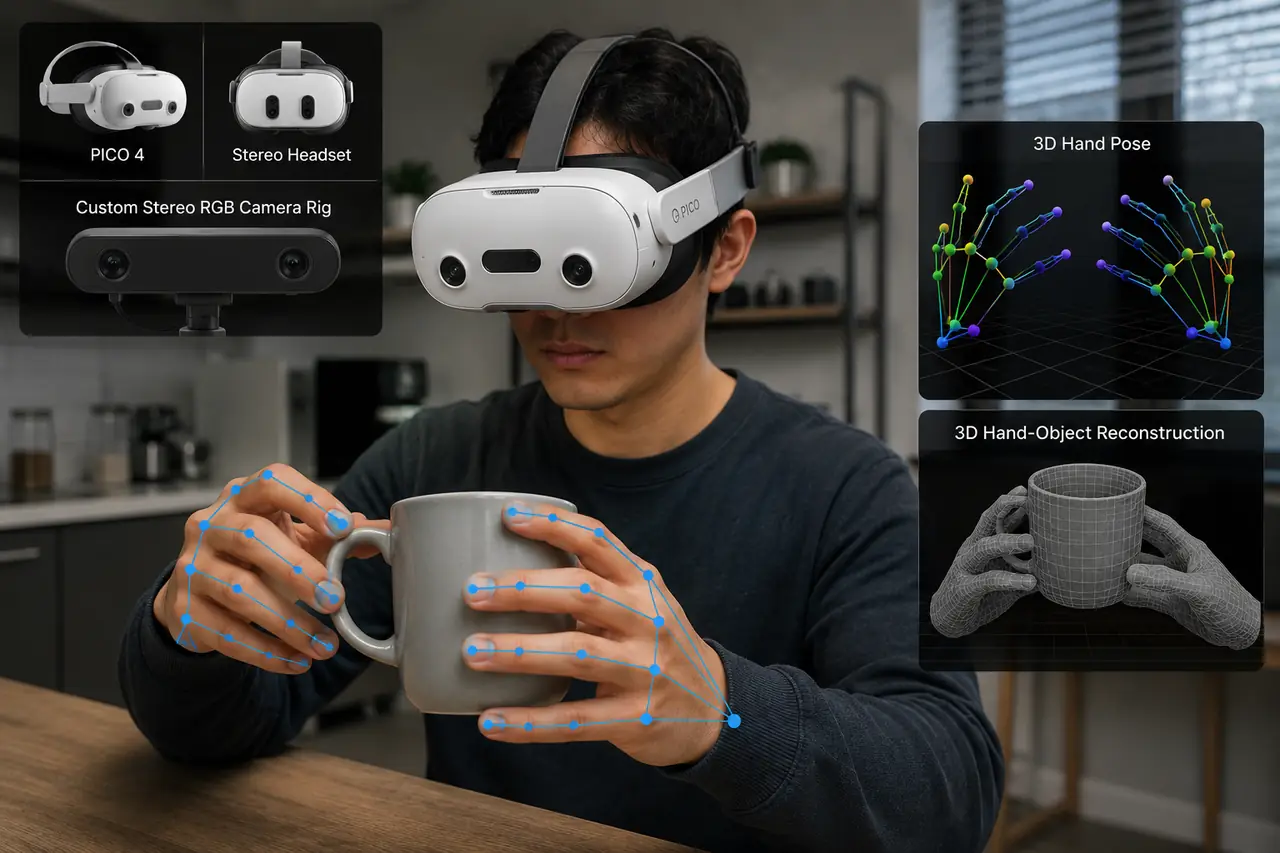
Egocentric capture using VR devices like Meta Quest or Pico, LiDAR devices, stereo headsets, or custom stereo camera rigs to generate stronger depth and 3D hand-object understanding than monocular RGB. Ideal for depth estimation, 3D hand pose estimation, hand-object tracking, spatial reasoning, and manipulation research.
Capture setup
iPhone with LiDAR, Meta Quest, Pico, stereo headsets, or custom stereo RGB camera rigs.
Key distinction
Ego Depth improves 3D estimation using richer visual and depth signals. It is ideal when you need better spatial understanding, but hand keypoints may still need to be estimated when fingers are hidden or occluded.
Deliverables
RGB-D or stereo video, depth outputs where applicable, synchronized streams, task metadata, interaction segments, and optional estimated 3D hand pose.
Sample dataset
Show short clips such as pouring liquids into containers, opening drawers and cabinets, picking objects from shelves, assembling small parts, or navigating cluttered spaces.
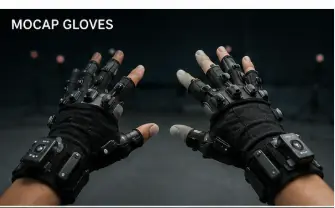
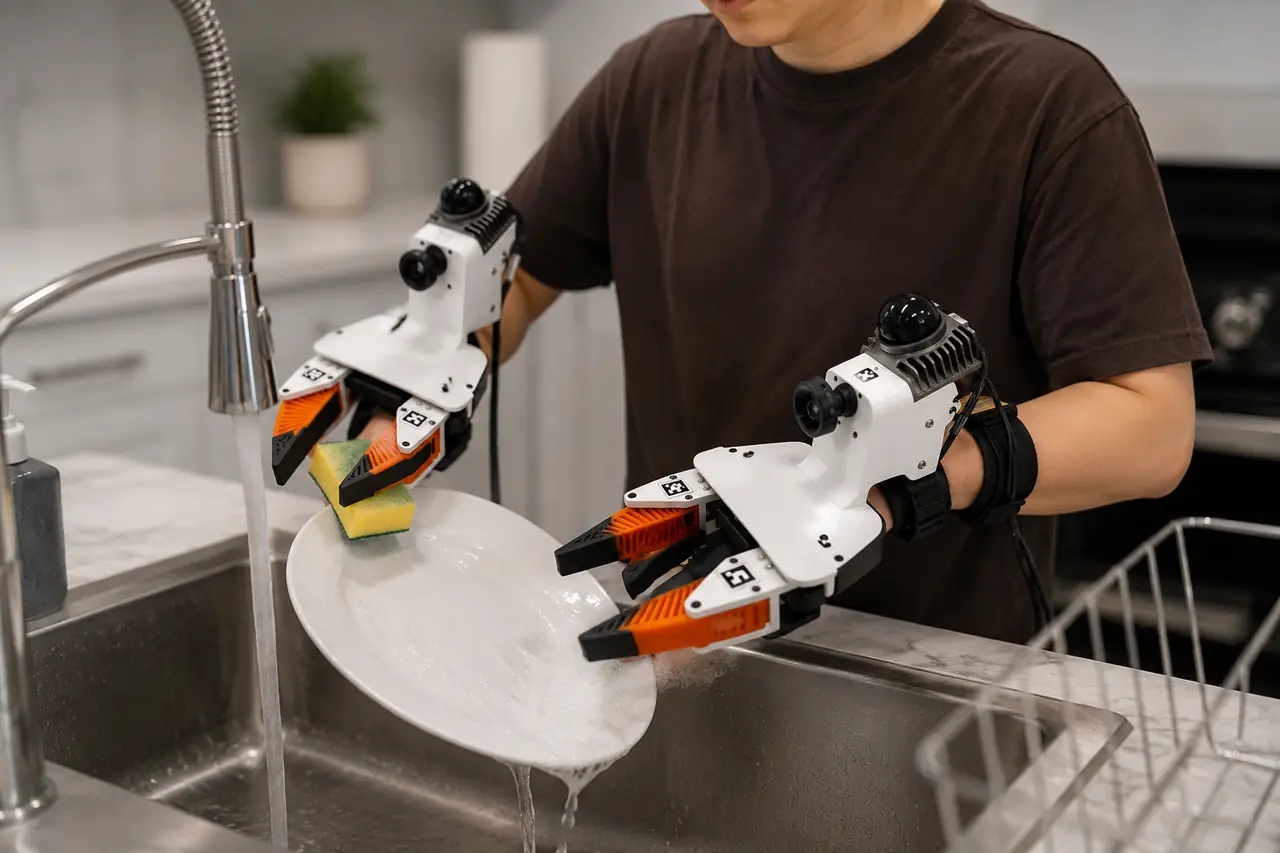
Absolute 3D hand pose ground truth with mocap gloves
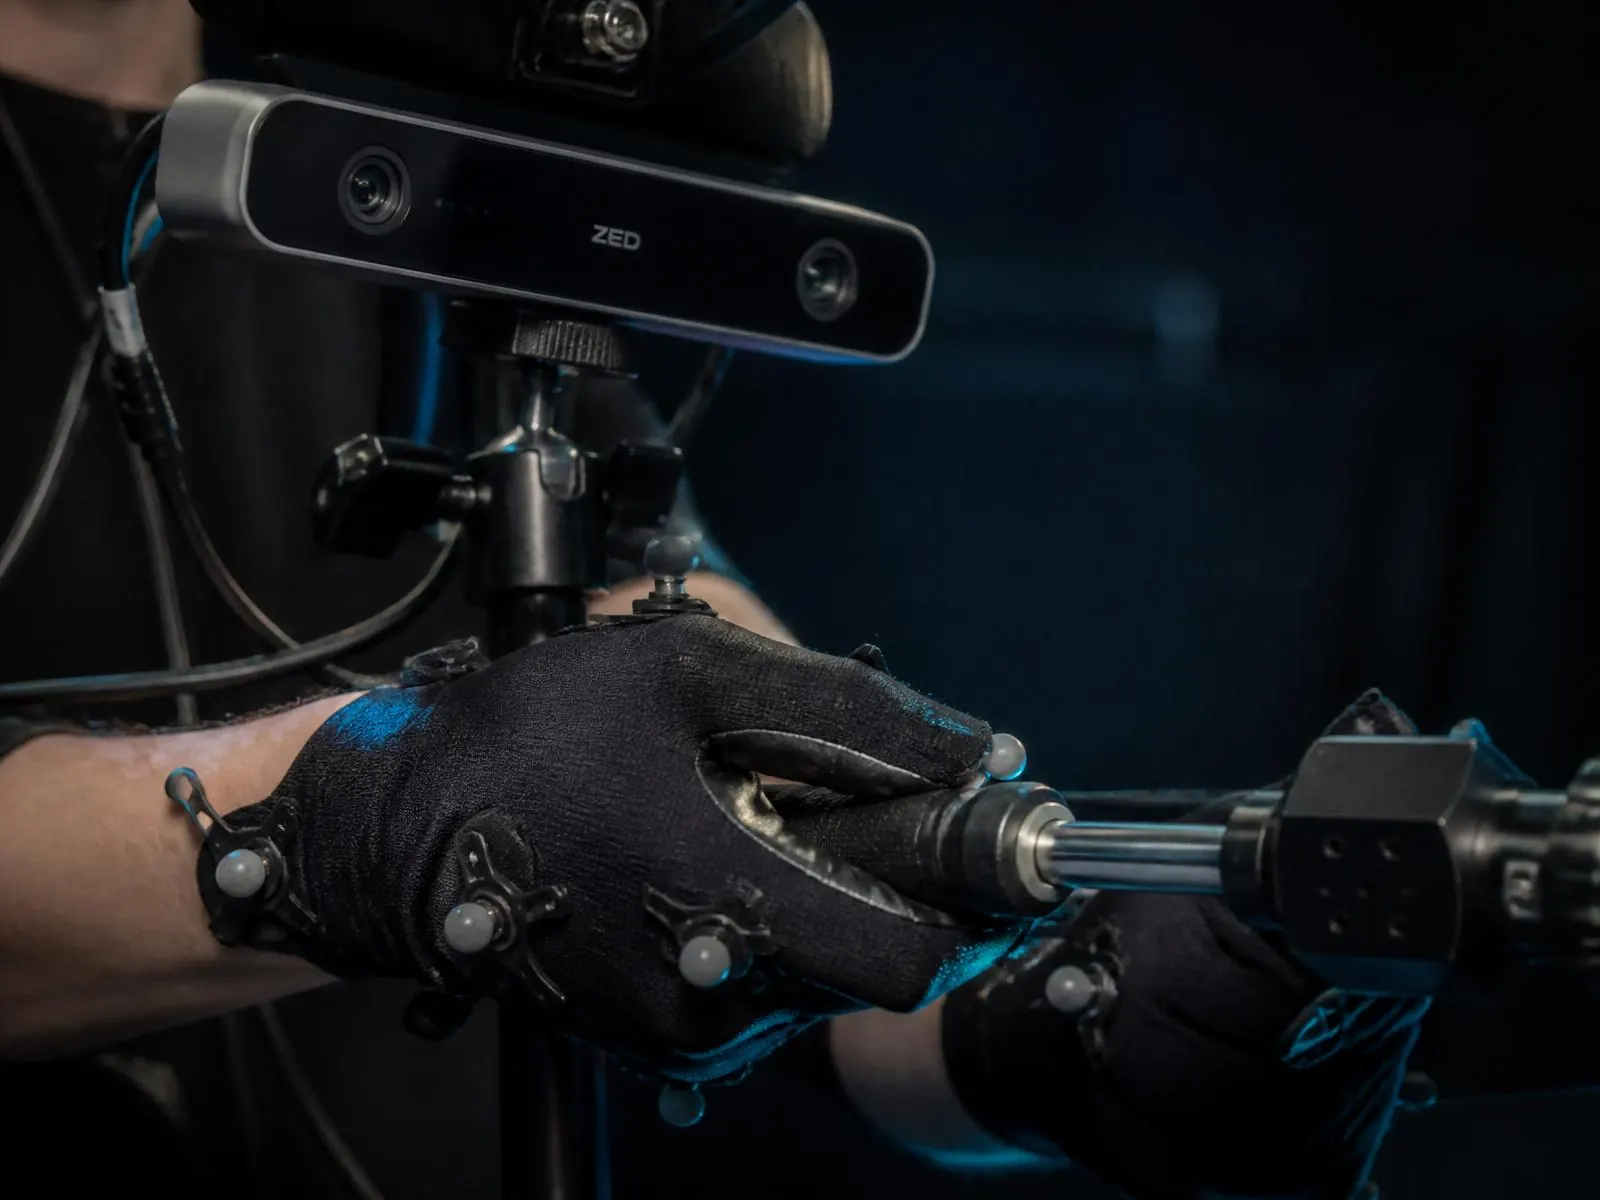
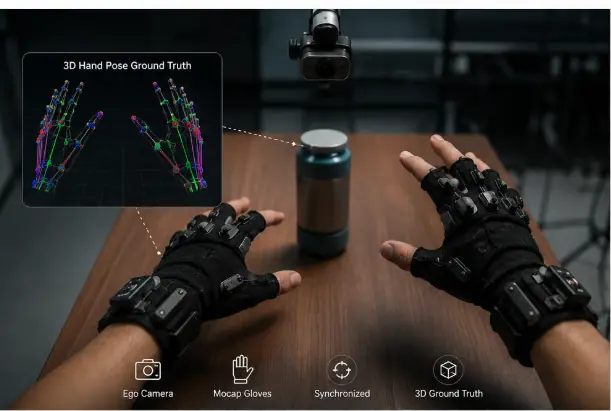
Ego camera capture combined with wrist cams to provide true hand pose ground truth, including keypoints that are visually occluded in the egocentric camera view. Ideal for high-precision hand pose datasets, dexterous manipulation, benchmark creation, policy learning, and model evaluation.
Capture setup
Ego camera + mocap gloves, with optional wrist cameras, stereo rigs, VR headsets, and synchronized sensors.
Key distinction
Unlike RGB, RGB-D, or stereo-based pipelines, Ego 3D Ultra does not rely on visual estimation for occluded hand keypoints. Mocap gloves capture the ground truth directly.
Deliverables
Egocentric video, absolute hand pose ground truth, occlusion-aware hand keypoints, synchronized sensor streams, task metadata, and optional semantic labels.
Sample dataset
Show short clips of dexterous manipulation such as grasping tools, handling small objects, opening containers, assembling parts, or occluded hand poses.
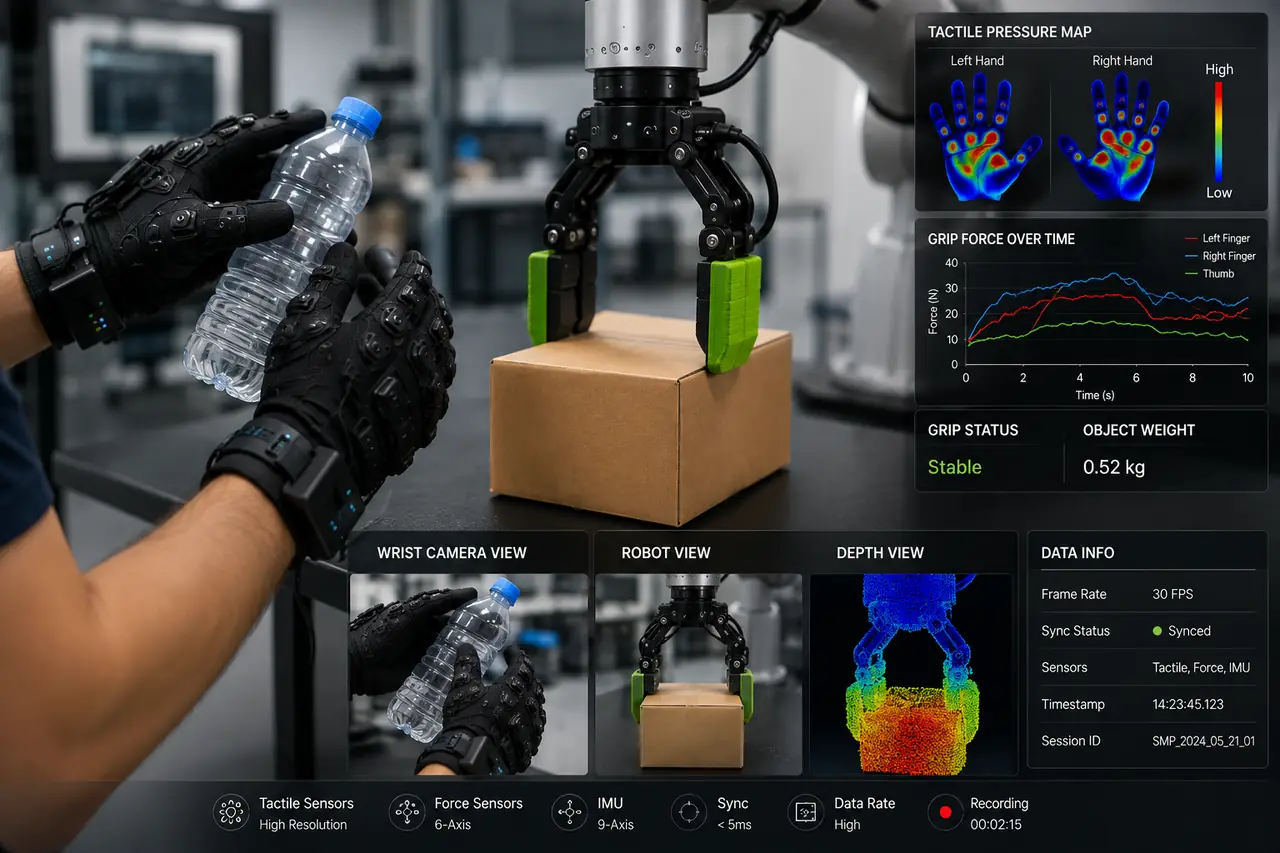
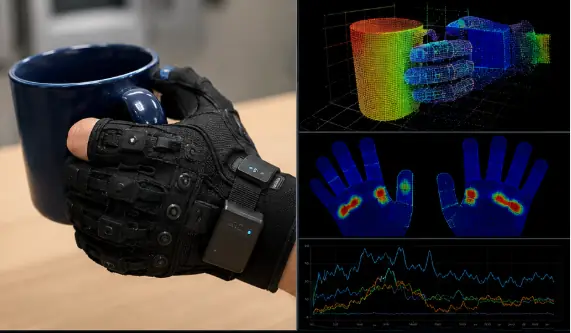
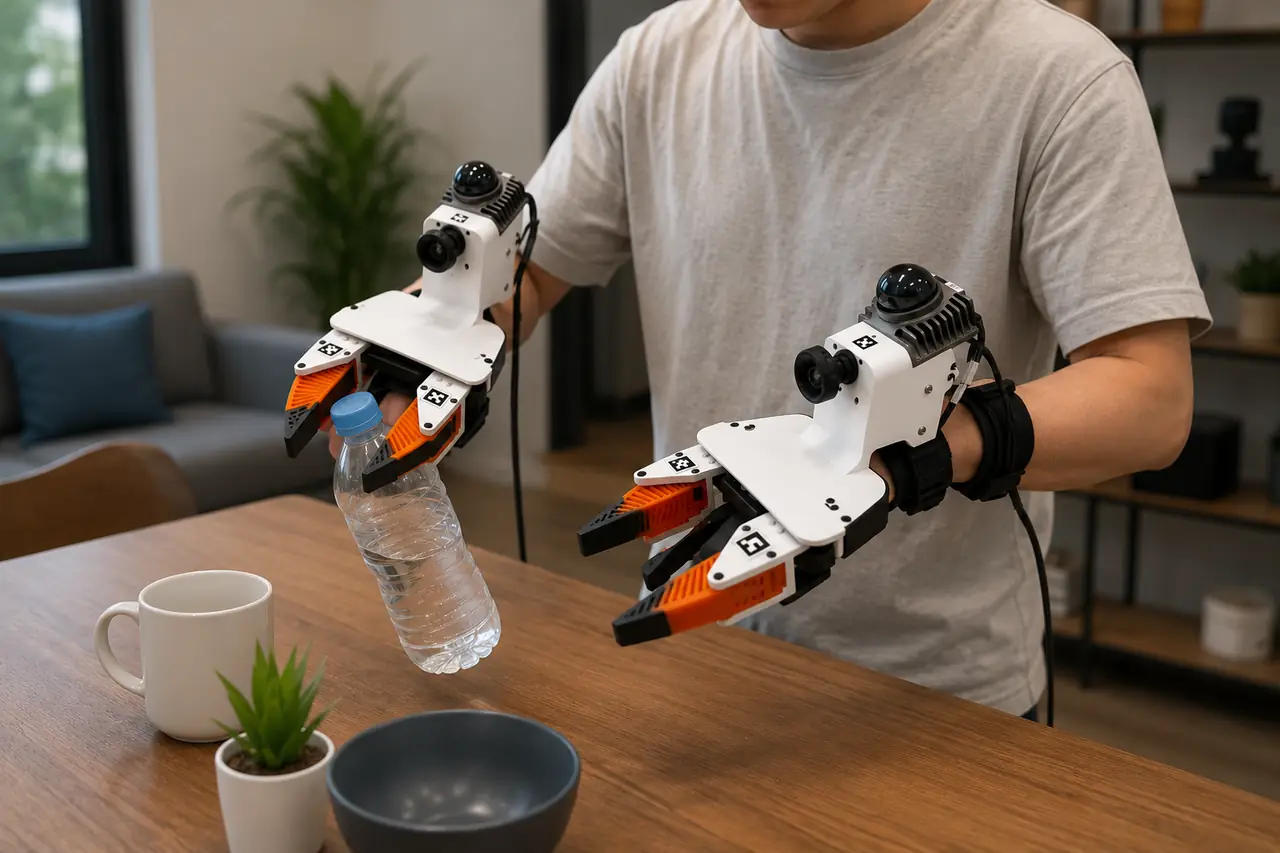
Capture how humans touch, grasp, press, hold, lift, move, and release objects using tactile and contact-sensing hardware. Ideal for grasping, force-aware manipulation, tactile learning, dexterity, and contact prediction.
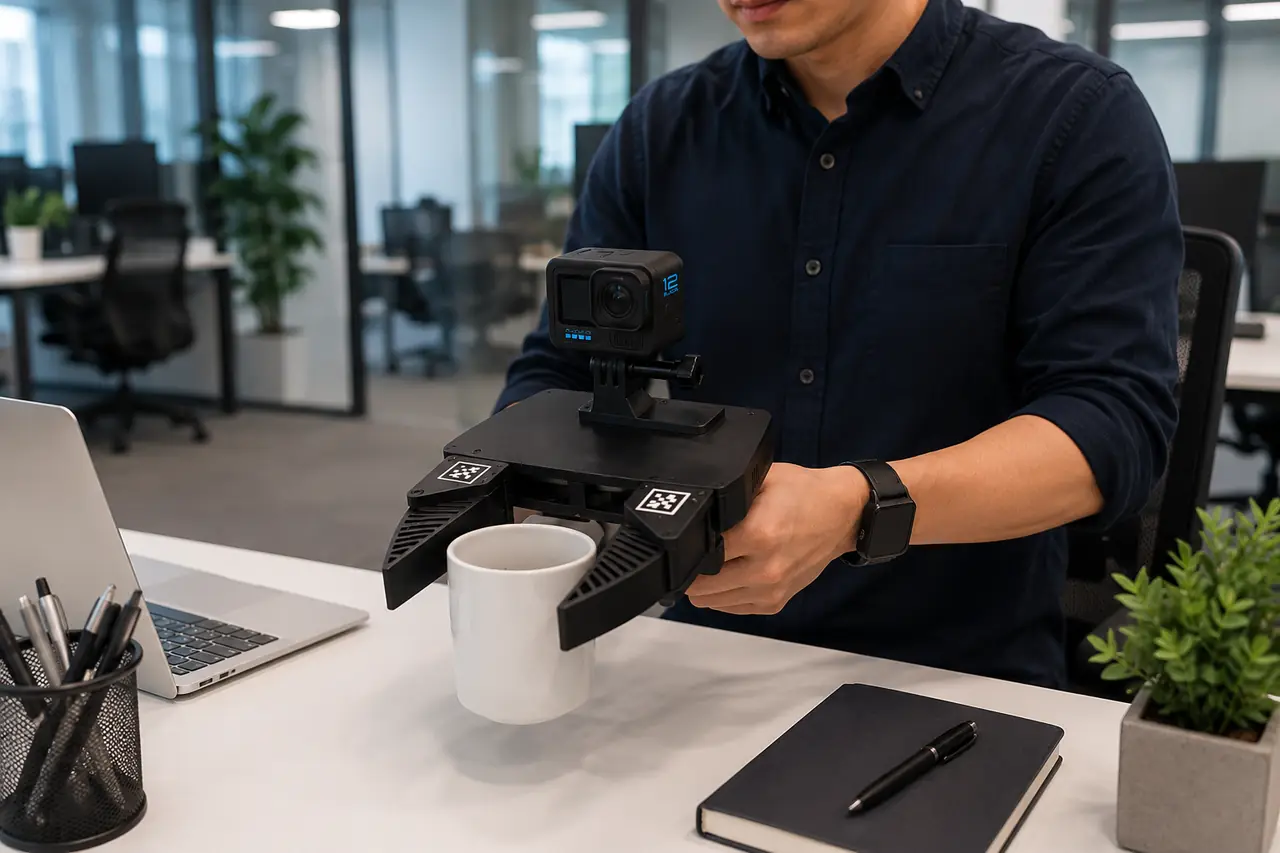
Show short clips of contact-rich manipulation such as grasping a mug, lifting a box, holding a tool, pressing a button, or interacting with deformable objects.
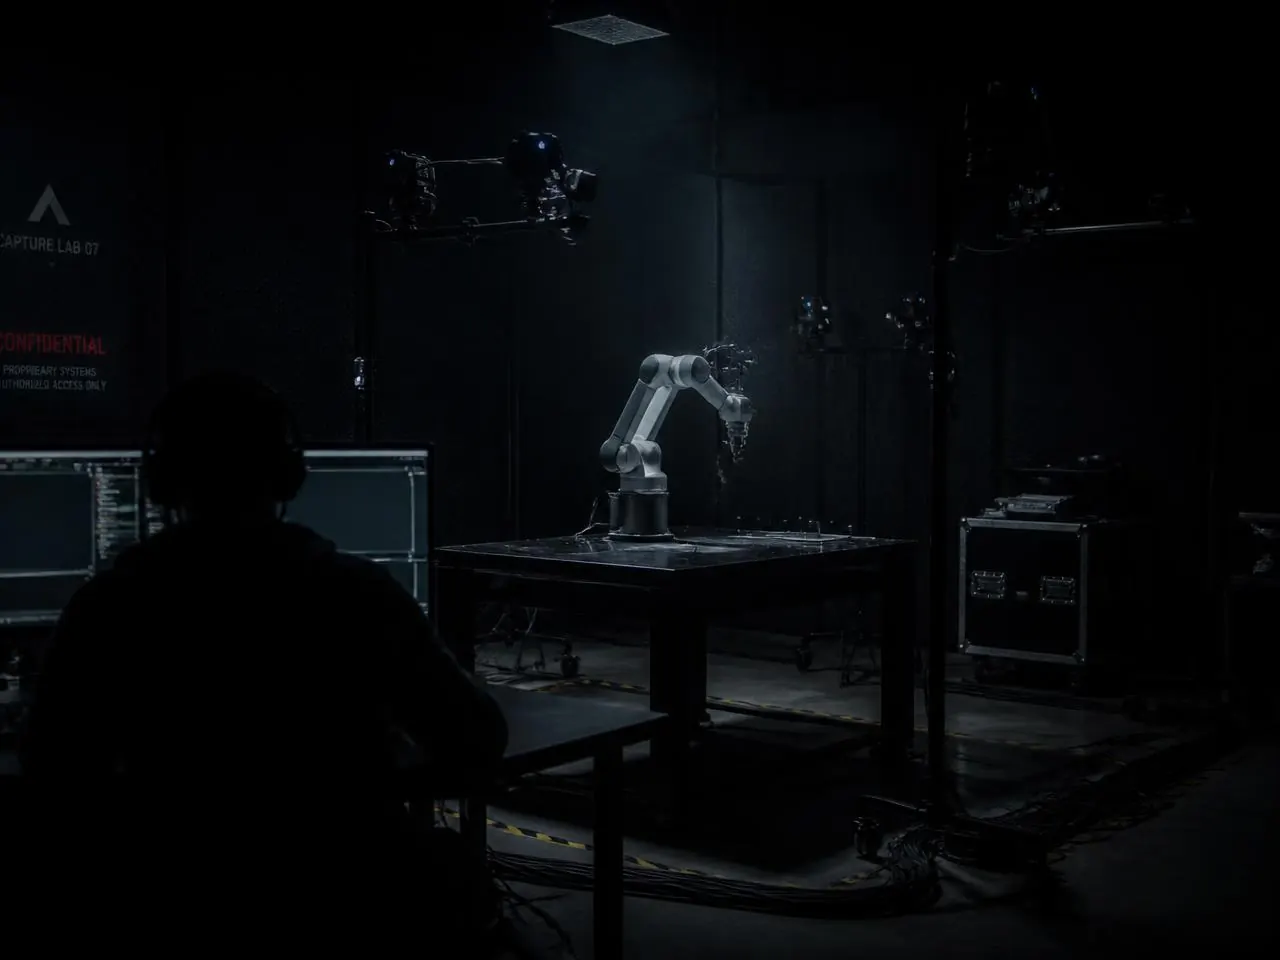
For robotics teams with unique hardware, confidential capture systems, custom rigs, robot interfaces, or proprietary workflows. You bring the stack; Awign finds or recreates the right environment, deploys trained workers, runs the SOP, and manages large-scale operations in India.
What Awign handles
Environment sourcing or recreation
Worker recruitment and training
Hardware handling and deployment
SOP execution
Shift planning and supervision
Data capture QA
Stealth operations at scale
Deliverables
Whatever your system requires: video, sensor logs, robot logs, teleop logs, metadata, QA reports, or annotation-ready datasets.
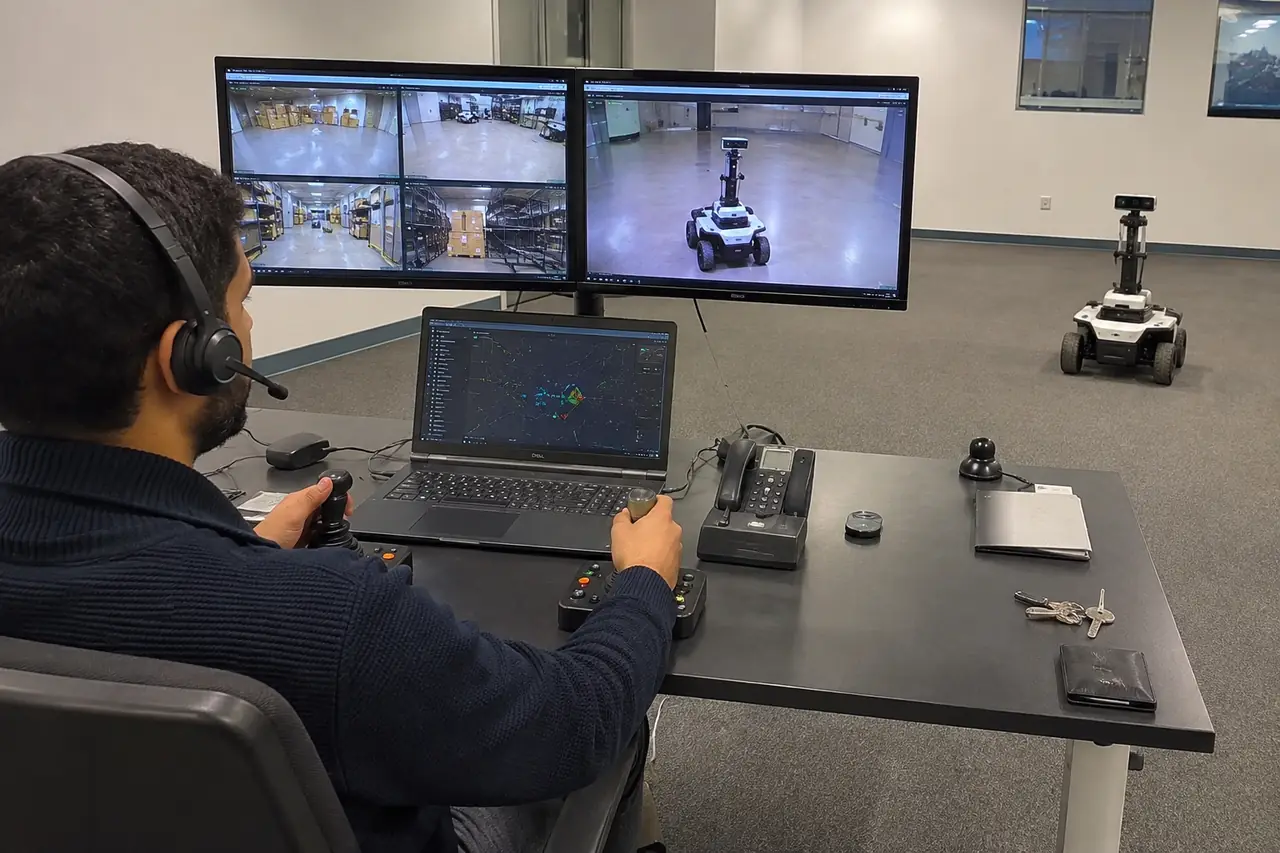
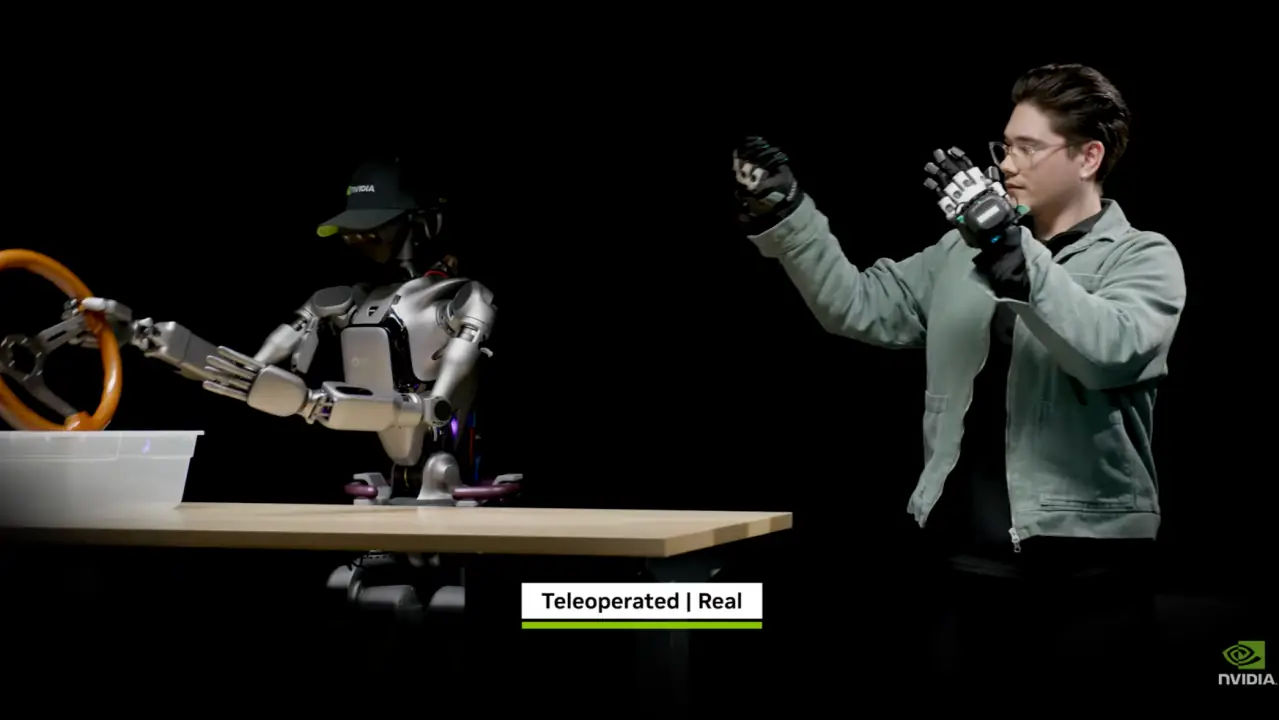
Teleoperations as a Service
Remote operators for robot control and data generation
Awign provides trained remote operators to control robots, run demonstrations, monitor systems, handle interventions, and generate policy data for robot learning, remote manipulation, simulation control, fleet monitoring, and policy evaluation.
What Awign handles
Operator hiring, training, certification, scheduling, productivity tracking, QA, and reporting.
Deliverables
Teleop recordings, operator action logs, robot camera feeds, intervention records, task success/failure labels, and session metadata.
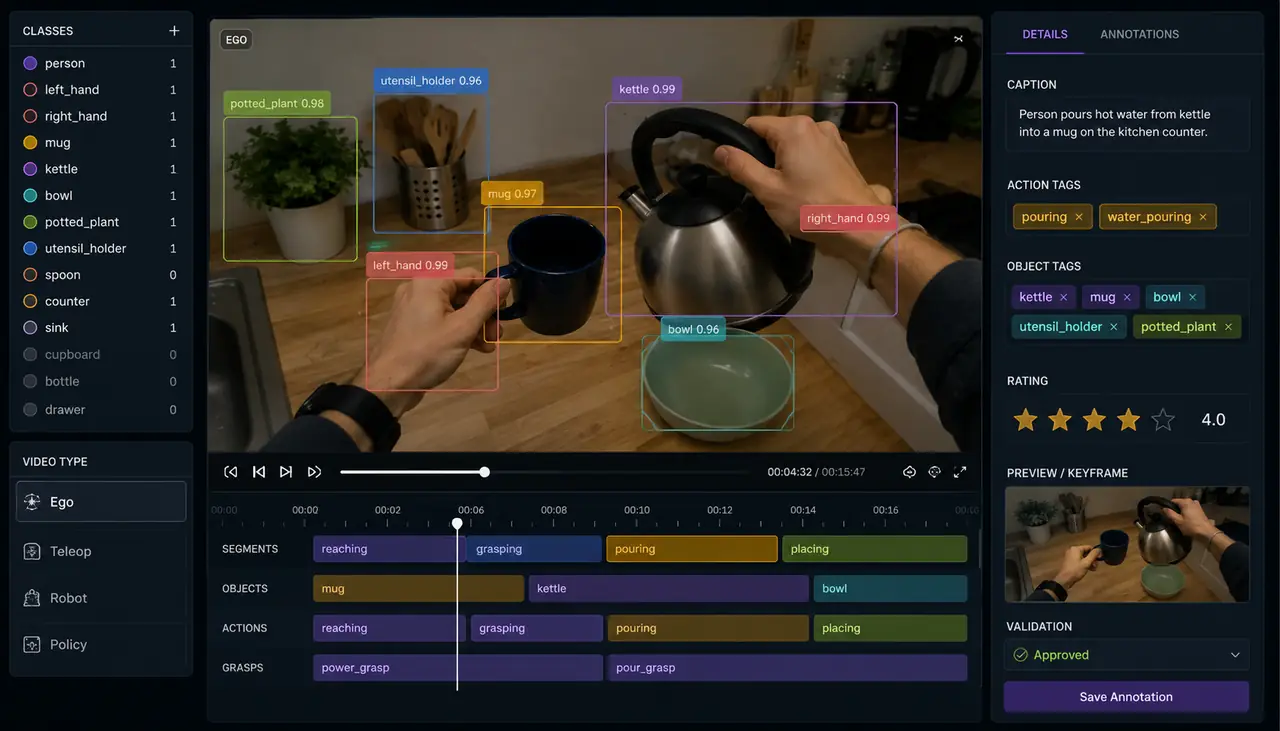
Turn robotics videos into structured training data
Awign segments, labels, captions, rates, and validates ego, teleop, robot, and policy videos using VLM-assisted workflows and human-in-the-loop review. Ideal for long-horizon robotics videos, egocentric datasets, policy evaluation, failure analysis, and action-level training data.
Action segmentation, contact event labels, 3D hand pose, tactile signals, and HITL QA.
Sample dataset
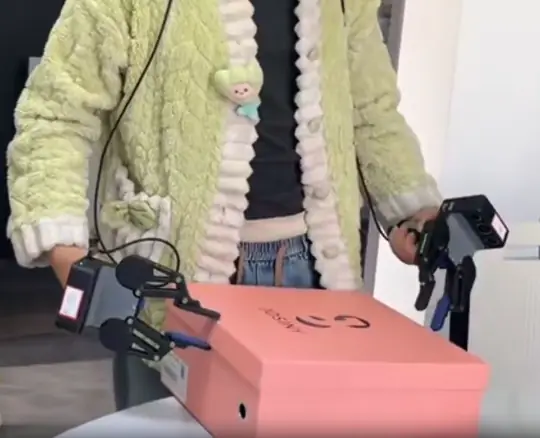
Show short clips of grasping and manipulating objects with UMI, 2-finger, and custom grippers, including pick-and-place, tool use, and in-hand repositioning.
We protect your data with secure storage, controlled access, PII protection, and privacy-first collection practices. From consent and data capture to storage and
delivery, we follow strict security protocols to keep your data safe and confidential.
How it works
From Requirements to Production-Ready Data
From setup to delivery, we manage your robotics data pipeline at scale.
Step 1
Define the requirement
Tasks, hardware, environment, output format, volume, and quality bar.
Step 2
Design the SOP
We convert your requirement into worker instructions, QA rules, escalation paths, and delivery specs.
Step 3
Set up the environment
We source, partner with, or recreate the required environment in India.
Step 4
Deploy the workforce
Workers are trained, scheduled, monitored, and managed by Awign.
Batch-level QA, issue tracking, rework loops, metadata, and structured delivery.
Build Your Robotics Data Pipeline in India
Start with a pilot. Scale into a dedicated production line for egocentric video, depth data, mocap ground truth, tactile data, teleoperation, BYOS, or semantic
annotation.
Get pricing, sample datasets, and a project plan within 24 hours.
Get clear answers to help you choose the right egocentric data collection service and scale your AI and robotics projects with confidence.
Frequently Asked Questions
Where can robotics companies get Physical AI training data?
Awign provides Physical AI training data collection services for robotics companies, AI labs, and humanoid robotics teams. We collect real-world human demonstrations, egocentric video, multimodal sensor data, and task-specific datasets for robot learning, embodied AI, Physical AI, and robotics model training.
What is egocentric data collection for robotics and Physical AI?
Egocentric data collection captures first-person video and sensor data from a human perspective using wearable, head-mounted, wrist-mounted, or other camera configurations. This data helps AI systems learn human actions, object interactions, manipulation behaviors, environments, and real-world task execution.
What types of robotics training data can Awign collect?
Awign can collect egocentric video, (first-person video/POV), human demonstration data, manipulation data, multimodal datasets, multi-camera recordings, and sensor data. Collection can be customized based on the required robotics tasks, environments, hardware, metadata, data formats, and quality specifications.
Can Awign collect multimodal data for Physical AI and VLA models?
Yes. Awign can create multimodal Physical AI datasets combining visual, motion, interaction, and sensor information. Depending on project requirements, datasets can include stereo cameras, wrist cameras, IMU sensors, tactile sensors, robotic grippers, and UMI systems for Vision-Language-Action (VLA), embodied AI, and robot learning.
What cameras and sensors can Awign use for robotics data collection?
Awign supports a range of robotics data collection hardware, including custom monocular cameras, stereo cameras, iPhones, Android phones, wrist cameras, wearable cameras, GoPro cameras, IMU sensors, tactile sensors, robotic grippers, and UMI systems. Hardware configurations can be selected based on the training signals and dataset requirements.
Can Awign collect human demonstrations for robot manipulation and imitation learning?
Yes. Awign can collect human demonstration and fine-grained manipulation data for tasks such as grasping, picking and placing, pouring, cutting, assembling, folding, fastening, cooking, cleaning, tool use, and other human-object interactions. These demonstrations can support imitation learning, robot manipulation, robot learning, and Physical AI training.
Can Awign provide training data for humanoid robots and embodied AI?
Yes. Awign can design data collection programs for humanoid robots, embodied AI, robot learning, and Physical AI. Programs can capture human activities, demonstrations, and interactions across real-world environments to help AI models learn physical tasks, human actions, and human-object interactions.
What environments can Awign cover for robotics data collection?
Awign can collect real-world robotics data across household and residential environments, retail, commercial spaces, warehouses, manufacturing facilities, workshops, agriculture, and workplaces. Data collection can be organized around specific environments, scenarios, task taxonomies, and environmental conditions.
How does Awign ensure robotics data quality, privacy, and security?
Awign combines automated validation and human quality assurance to evaluate framing, motion quality, task compliance, duration, synchronization, and metadata completeness. Collection workflows can also incorporate participant consent, privacy controls, PII protection, bystander privacy protocols, and client-specific data security requirements.
Can Awign scale custom Physical AI and robotics data collection programs?
Yes. Awign can design and scale custom Physical AI and robotics data collection programs based on task, environment, geography, hardware, sensors, dataset volume, metadata schema, and quality requirements. Programs can combine egocentric video, stereo and wrist cameras, IMU, tactile, gripper, UMI, and other multimodal data to create specialized datasets for robotics, humanoid robots, Physical AI, embodied AI, and VLA models.